
基本信息
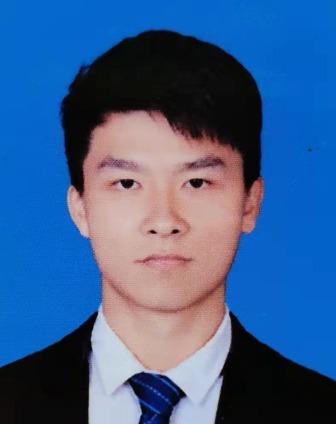
伍湘,湖南益阳人,工学博士。以第一作者身份发表SCI期刊论文4篇。从事欠驱动系统的建模与控制、移动机器人系统控制、欠驱动航天器姿态控制等领域研究。联系方式:email:wuxiang@shu.edu.cn。
教育背景
2015-2019:石家庄铁道大学,获工学学士学位;
2019-2022:上海大学,获工学硕士学位;
2022-2026:上海大学,获工学博士学位。
工作履历
2026.7-至今:湖南工商大学前沿交叉与未来技术学院,专任教师
教授课程
暂无
研究领域
控制器设计与稳定性分析
移动机器人控制:定点镇定、轨迹跟踪、多体协同和编队
欠驱动航天器姿态控制:单轴指向、单轴跟踪、全姿态镇定
科研项目
1.军工项目“航天器再入近空间模拟方法与神经网络代理模型”(23JZ00043),参与。
2.国家自然科学基金一般项目“多机械臂系统网络化协调模式的理论与控制策略研究”(51875331),参与。
3.国家自然科学基金一般项目“集群—车辆—农田共融环境下机器人系统区域作业的协同感知与编队控制”(52375107),参与。
4.国家自然科学基金一般项目“非完整Lagrange系统群集协调行为动力学建模与控制及其实验研究”(12072180),参与。
学术成果
主要论文:
1.X. Wu, X. Li, D. Zhang, Z. Li, J. Zhou. A control strategy for point stabilization and trajectory tracking of wheeled mobile robots[J]. Robotics and Autonomous Systems, 2025. (SCI,中科院2区,JCR 1区)
2.X. Wu, X. Li, Z. Li, D. Zhang, Z. Miao, J. Zhou. An improved Udwadia–Kalaba approach for controller design in underactuated mechanical systems[J]. Multibody System Dynamics, 2025. (SCI,中科院2区,JCR 2区)
3.X. Wu, X. Li, Z. Li, D. Zhang, J. Zhou, Y. Tian. Attitude Stabilization for Underactuated Spacecraft: A Piecewise Continuous Bounded Feedback Control Approach[J]. International Journal of Robust and Nonlinear Control, 2026. (SCI,中科院3区,JCR 1区)
4.X. Wu, X. Li, Z. Li, D. Zhang, J. Zhou, Y. Tian. Single-Axis Pointing for Underactuated Spacecraft Under Unknown External Torques[J]. Robotics and Autonomous Systems, 2026. (SIC,中科院2区,JCR 1区)
5.X. Wu, Z. Miao, J. Zhou. Tracking Control of Flexible-Joint Manipulator Based on Generalized Udwadia-Kalaba Equation[C]. In: Proceedings of 2021 Chinese Intelligent Systems Conference. Lecture Notes in Electrical Engineering, 2021. (EI)